🌟About Me
Last updated: 2026-03-30
I am currently a Ph.D. candidate in Transportation Engineering at Tongji University, supervised by Prof. Jian Sun. My research focuses on social behaviors in driving interactions and human-computer interaction (HCI) technologies for autonomous driving systems.
🔥 News
- 2026.03: 🎉 Our paper, “Every Scene All at Once: Exhaustive Multi-Agent Interaction Generation with Controlled Diffusion Model”, is now available on IEEE Xplore. paper
- 2026.02: 🔥 Our preprint, “Physics-Informed Interaction Modeling for Warning Targeting in Multi-Risk Driving Scenarios”, is now available on SSRN. paper
- 2026.01: 🎉 Our paper has been accepted by CHI 2026!
- 2025.07: 🔥 Our work, “A Naturalistic Trajectory Dataset with Dense Interaction for Autonomous Driving”, has been published in Scientific Data. paper |dataset |code
- 2025.07: 🎉 Our paper has been accepted by ITSC 2025!
📝 Publications
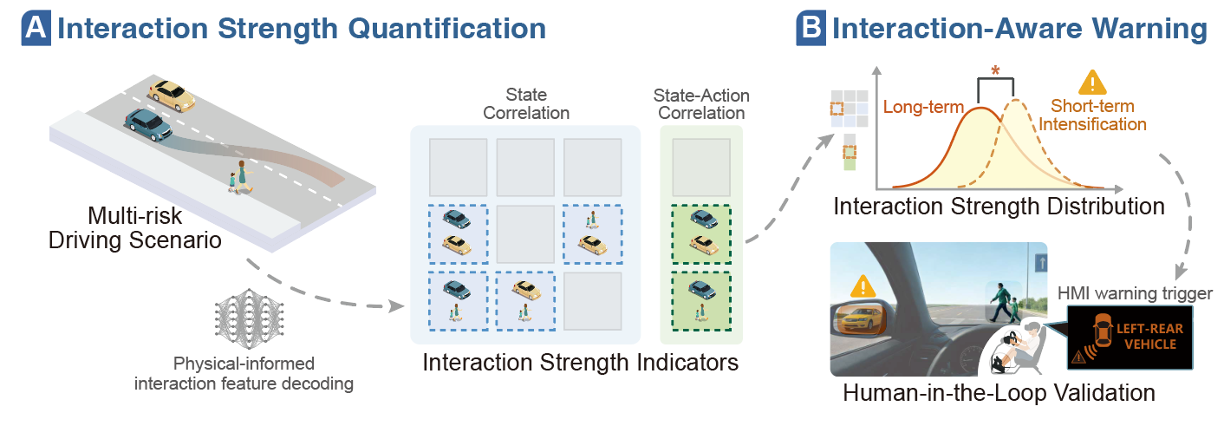
Jian Sun, Ruoxi Kong, Xiaocong Zhao, Haoyang Liang, Xiyan Jiang, and Yiru Liu
SSRN Preprint, 2026
-
A physics-informed interaction modeling framework makes ego-centric interaction semantics explicit and quantifiable for warning targeting in dense multi-risk traffic.
-
The interaction-aware HMI improves critical-agent identification and yields faster attention shifts with far fewer collisions in driver-in-the-loop virtual reality experiments.
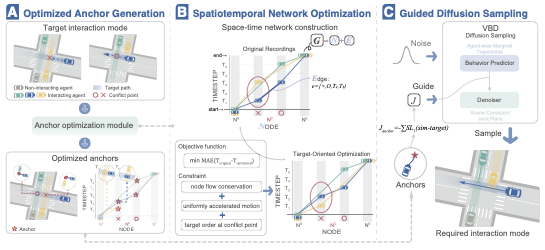
Xiyan Jiang, Xiaocong Zhao, Yiru Liu, Peng Hang, and Jian Sun
2025 IEEE 28th International Conference on Intelligent Transportation Systems (ITSC)
-
We enumerate all dynamically feasible multi-agent interaction modes in a scene by decomposing negotiations at conflict points and solving graph-based spatiotemporal anchors.
-
A controllable diffusion model then generates realistic full-scene trajectories, including low-probability but physically and socially plausible counterfactuals for AV testing.
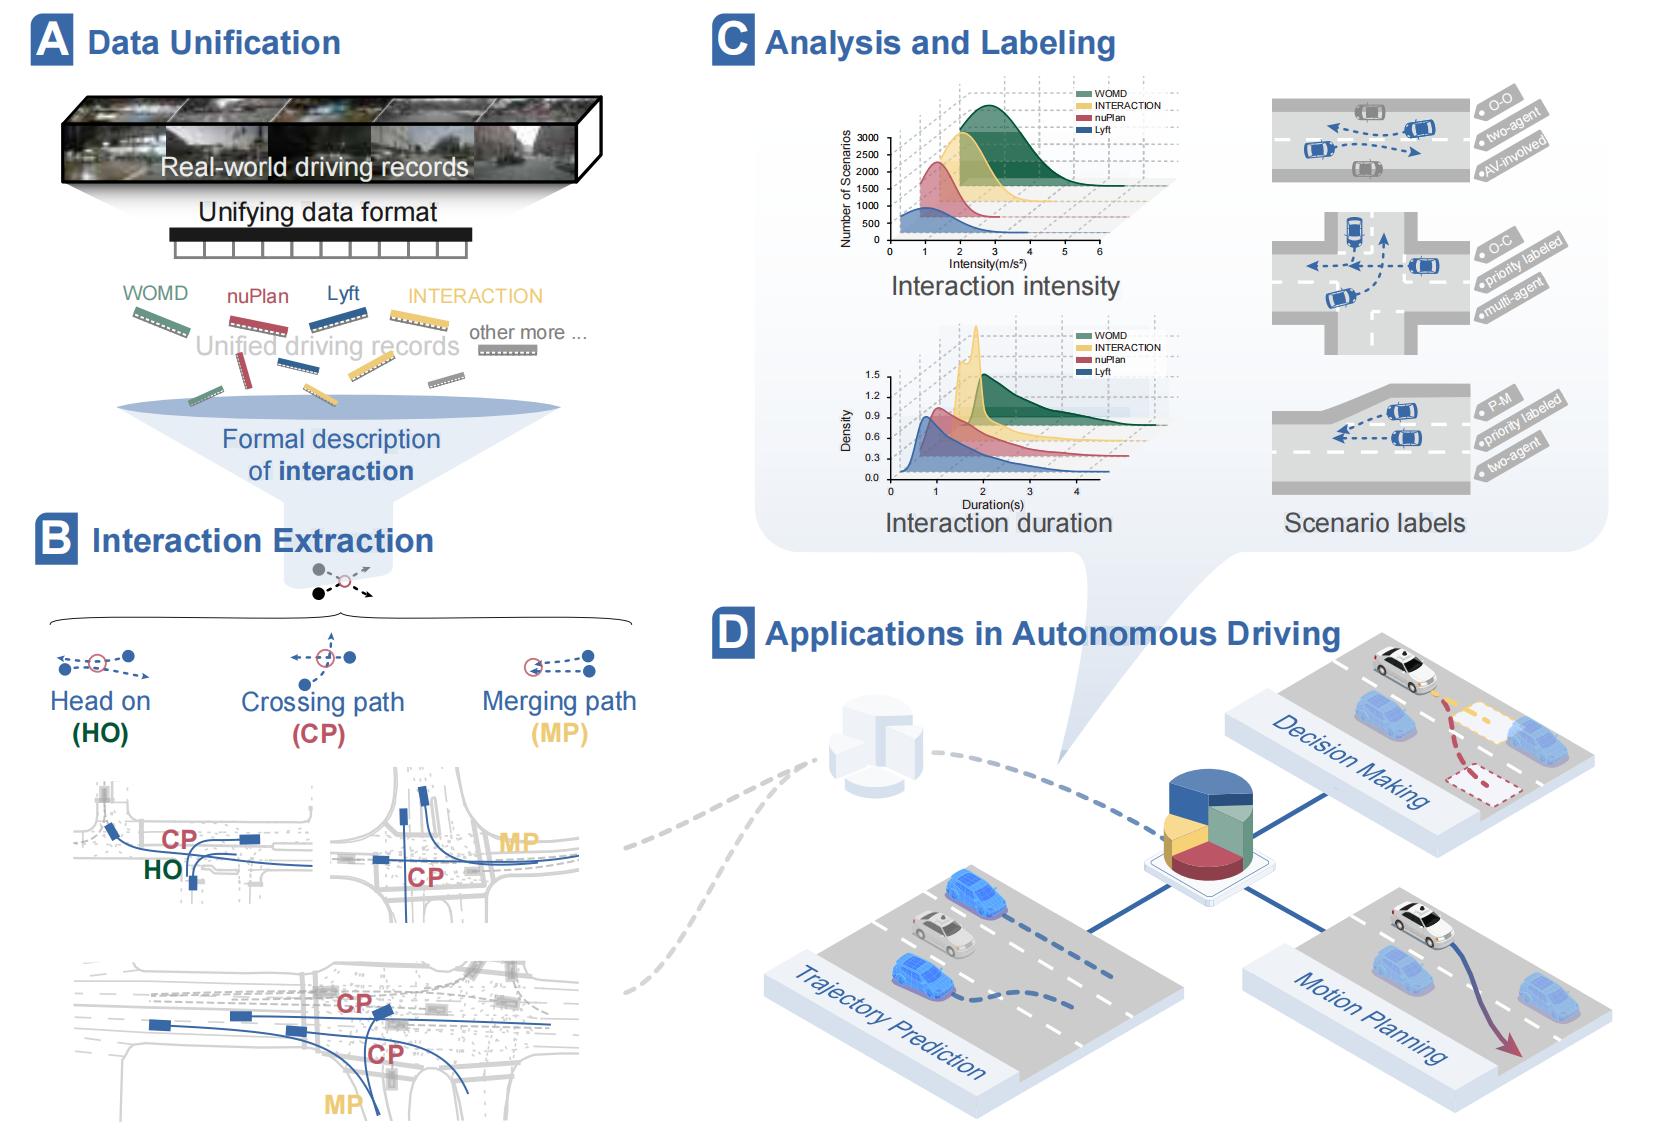
Xiyan Jiang, Xiaocong Zhao*, Yiru Liu, Zirui Li, Peng Hang, Lu Xiong, and Jian Sun
-
A unified naturalistic driving dataset with dense interactions is built by integrating and organizing multiple public datasets, providing a clear and accessible resource for studying complex traffic behaviors.
-
A formal, quantitative definition of driving interactions, paired with an open-source toolkit, enables effective analysis and application across autonomous driving tasks.
🎖 Honors and Awards
- 2025: Outstanding Doctoral Student Scholarship.
- 2020 - 2023: Outstanding Undergraduate Student Scholarship.
📖 Educations
- 2024.09 - now, Ph.D. in Transportation Engineering, College of Transportation, Tongji University, Shanghai.
- 2020.09 - 2024.06, Bachelor’s Degree in Transportation Engineering, College of Transportation, Tongji University, Shanghai.